
FILES TO READ, PRINT AND IMPROVE
Building in the open.
We share the available design, its checks, and everything that still needs a test on the workbench.
HARDWARE · V0.1
The prototype parts.
16 STL designs, their editable STEP files, 3 fit coupons and CAD review records. The manifest specifies 22 installed parts. The archive excludes commercial reference CAD and complete regeneration scripts.
Download public CAD · 3 MB ↓SHA-256: 2bb9d0a16be5155c1b3aeea75666b2387c16dc5fe18cab75c04b73e39a8045eb
Read the print guide and release scope ↗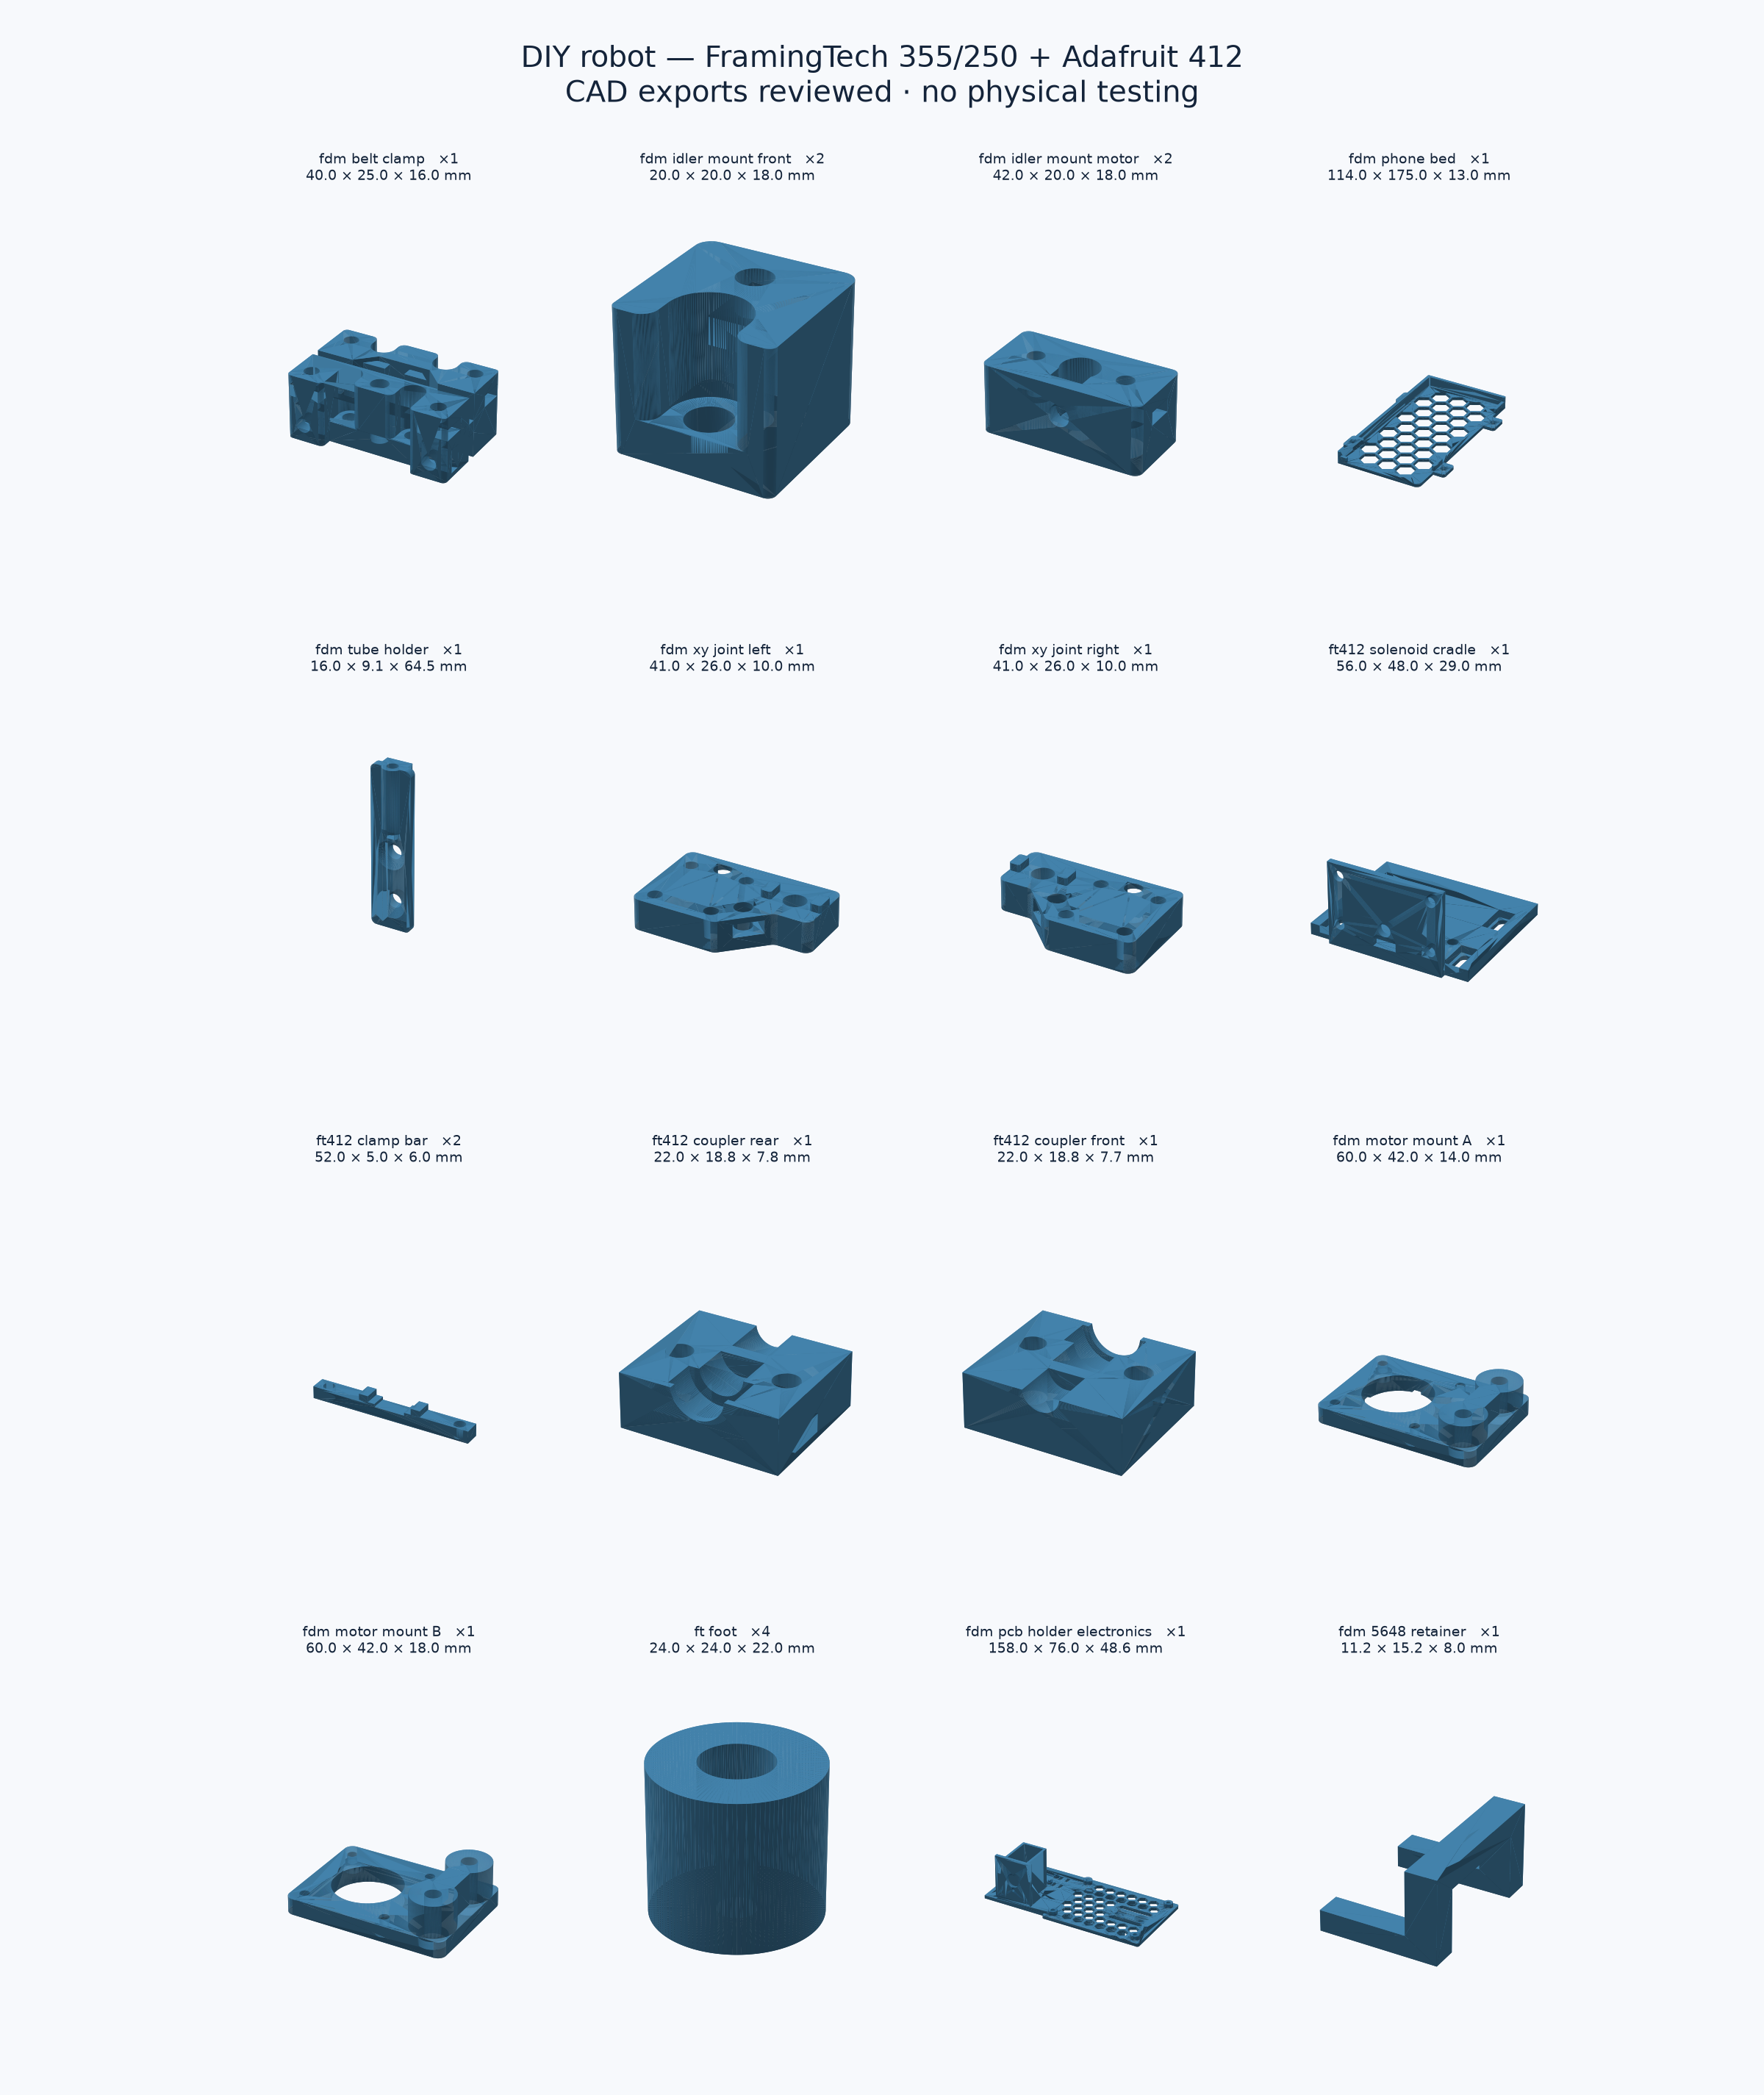
READ IN YOUR BROWSER / MARKDOWN SOURCE AVAILABLE
Build guides
The plan, the parts and the technical details for project 001.
Project guide ↗
Architecture, build sequence, contact limits and planned acceptance tests.
Read the guideGUIDE 02Parts and equipment ↗
All 74 equipment lines, current quote totals, the equipment allowance and product links.
Read the guideGUIDE 03Frame, motion and touch ↗
The FramingTech 355/250 and Adafruit 412 variant: configuration, printing and planned assembly.
Read the guideGUIDE 04Printed motor mounts ↗
Mounts A and B, fasteners, pulley positions, print orientation and prototype checks.
Read the guideGUIDE 05Electronics mount ↗
The DLC32, MOSFET driver and cutoff-switch holder, with installation and insulation notes.
Read the guideGUIDE 06Print files and release scope ↗
What is included in the public CAD release, quantities and the limits of digital validation.
Read the guideREAD IN YOUR BROWSER / MARKDOWN SOURCE AVAILABLE
Records and contributions
How the data, source and shared work are maintained.
Maintaining the ledger ↗
Quotes, allowances, orders, payments and shipments: how evidence becomes a public record.
Read the guideGUIDE 08Contributing ↗
Share a reproducible issue, a design improvement, a test result or an anonymized data correction.
Read the guideGUIDE 09Attribution and licenses ↗
The mechanical foundation, original notices, font license and publication scope.
Read the guideGUIDE 10Source and development ↗
Repository layout, local preview, checks and the GitHub Pages publication workflow.
Read the guideREAD IN YOUR BROWSER / MARKDOWN SOURCE AVAILABLE
Design and assets
The visual identity, artwork and prompts behind the journal.
Visual identity ↗
The blog name, Real World hero, robot cat mark, palette, typography and editorial voice.
Read the guideGUIDE 12Hardware illustration ↗
The reusable visual brief for raw concept sketches, kept separate from manufacturing CAD.
Read the guideGUIDE 13Robot cat logo ↗
The original logo prompt, generation mode and transparent image files.
Read the guideOur transparency rules
- Keep the evidence. Original documents stay private. We publish the relevant amounts and statuses, without addresses or private identifiers.
- Keep estimates distinct from facts. Quoted, ordered, paid, shipped and delivered are distinct states. Unknown does not mean zero.
- Avoid double counting. Grouped expenses included in an order are not added again. Tax and shipping are explained separately when evidence is available.
- Record corrections. Data updates are tracked in Git; journal entries keep their dated context.
- Publish technical limits. Each test will document its setup, conditions, results and failures. CAD is not presented as evidence of unproven reliability.
Origin and license
The mechanical foundation derives from PhysiClaw, hardware v0.51, under MIT. We retain its notice and document our modifications. The blog and our contributions are published under MIT. Read the attribution and release scope.
What is not published yet
The complete robot software, regeneration scripts and physical test results will be added as they are developed and validated. This initial site documents the start; it does not present those stages as complete.